
Talos Walker Technology
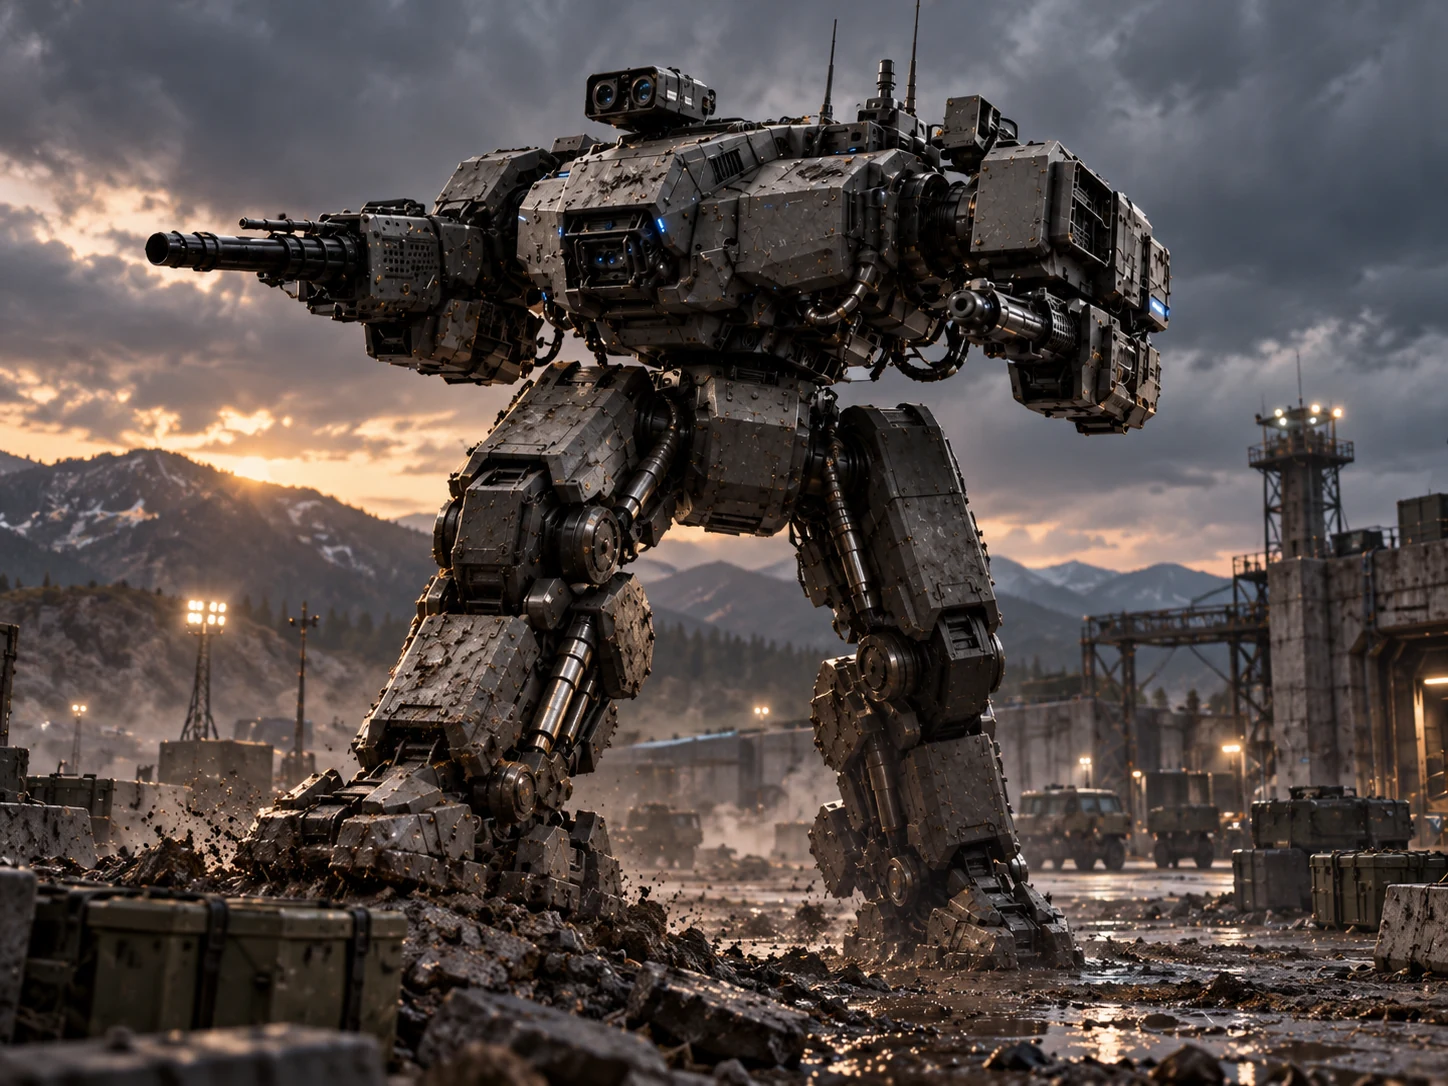
A system-architecture interpretation of the technologies that make the platform plausible within GloboTech’s established world and visual language.
Technical overview
Load-Bearing Structure
The platform is interpreted around a deep structural spine that routes recoil, payload and locomotion loads into widely spaced hip and leg assemblies.
Bipedal Stabilization
Distributed inertial sensing and active joint control maintain the vehicle’s center of mass during stepping, turning and firing cycles.
Power Distribution
Multiple protected power buses are assumed so mobility, sensors and defensive subsystems can remain available after localized damage.
Heavy Sensor Mast
Elevated optics and radar-class sensors provide awareness beyond the walker’s physical bulk and support coordination with shorter-range units.
Thermal Management
Large armored volumes, redundant cooling paths and heat-exchange surfaces are treated as necessary for sustained operation of a high-energy superheavy platform.
Restricted Maintenance
Major joints and mission systems are depicted as depot-level assemblies; detailed specifications remain classified in keeping with the source material.
Reference basis & canon notes
Canonical claims on this page are limited to what these references support. Technical subsystem descriptions marked or presented as engineering interpretation are original worldbuilding for this fan-made database.