
Sentinel Walker Technology
A system-architecture interpretation of the technologies that make the platform plausible within GloboTech’s established world and visual language.
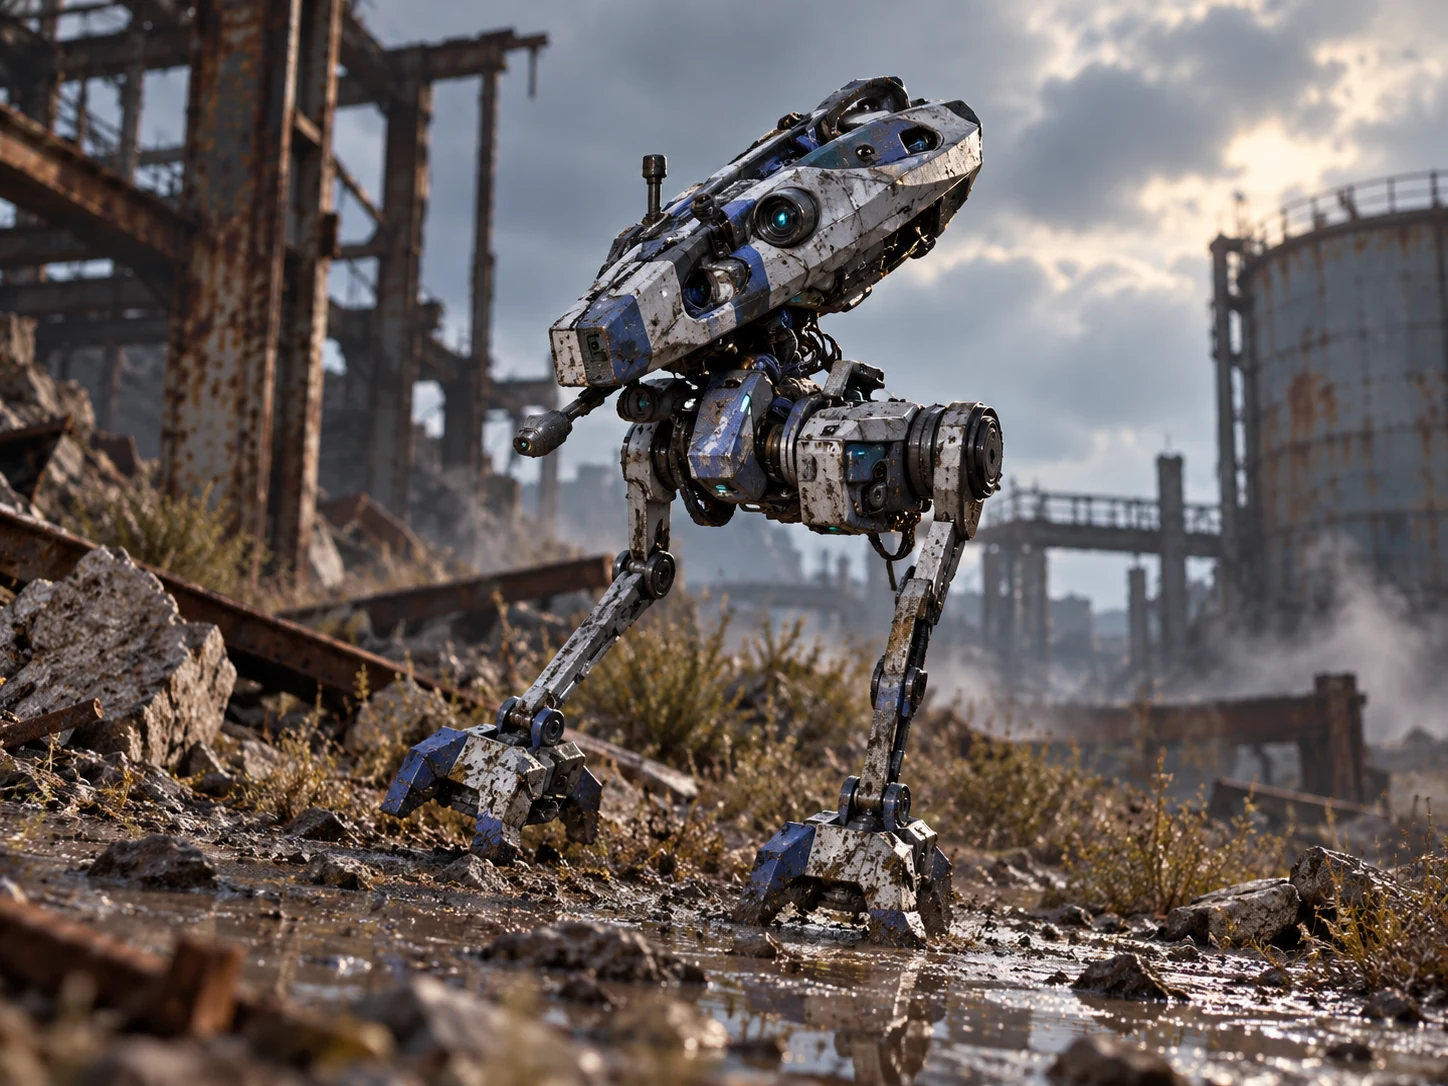
Technical overview
Autonomous Navigation
The system is interpreted around route planning, obstacle classification and supervised autonomy, with human command authority retained at the network level.
Legged Mobility
Long-stroke joints and distributed actuators provide step-over capability where wheeled vehicles would be constrained by rubble, piping or broken pavement.
Sensor Fusion
Optical and environmental sensors are combined into a local situational model for perimeter patrol, target classification and route safety.
Supervisory Control
Operators can retask patrol sectors, review alerts and impose engagement restrictions without continuously piloting the walker.
Service-Depot Dependency
Consistent with the source material, the autonomy stack is treated as delicate and calibration-intensive; major work is therefore reserved for equipped service facilities.
Fail-Safe Behavior
Loss of communication, degraded sensors or actuator faults trigger conservative movement and recovery behavior instead of uncontrolled autonomous action.
Reference basis & canon notes
Canonical claims on this page are limited to what these references support. Technical subsystem descriptions marked or presented as engineering interpretation are original worldbuilding for this fan-made database.